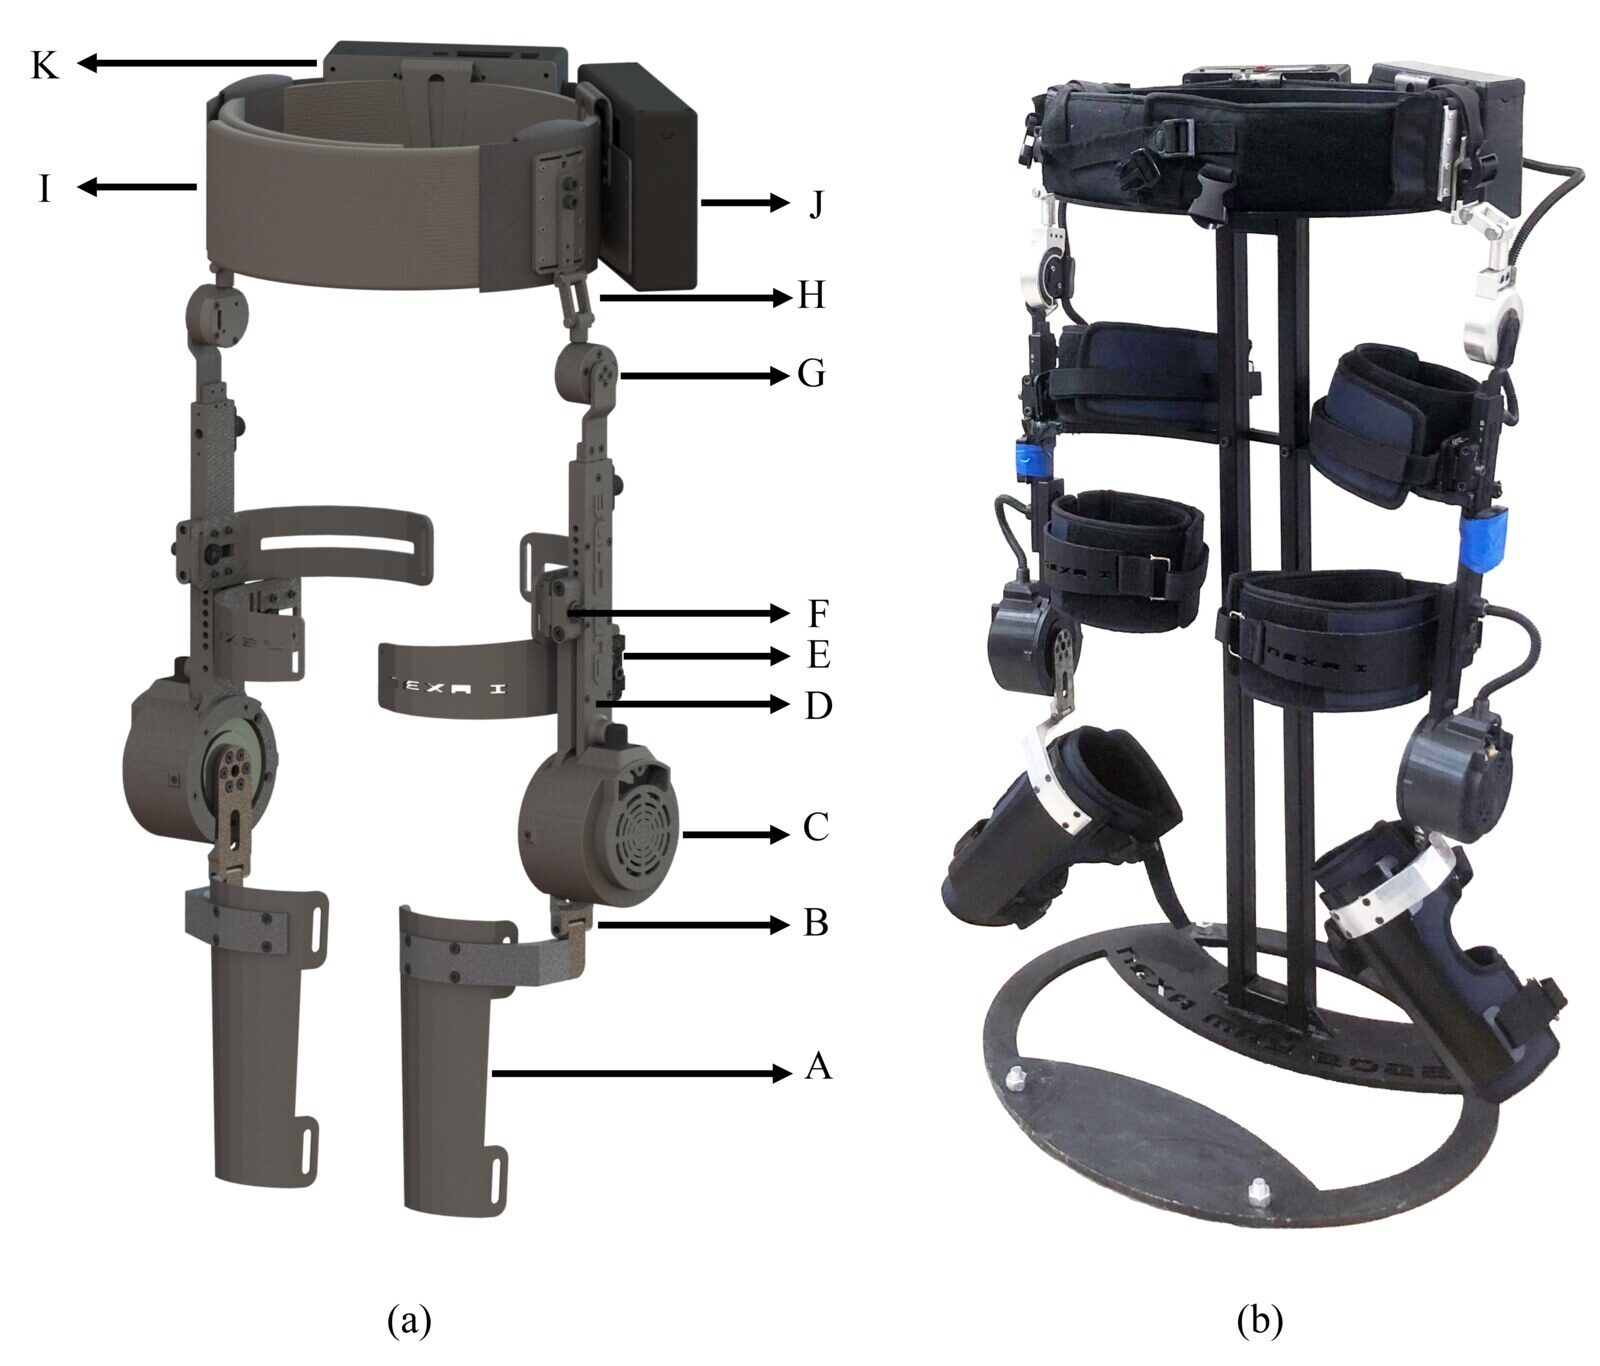
FUM-NEXA knee exoskeleton shown as a CAD design and as the manufactured prototype.

Adaptive sit-to-stand assistance for the FUM-NEXA knee exoskeleton

A fuzzy Strength Index adapts knee-exoskeleton torque during sit-to-stand in real time on a Raspberry Pi running ROS2. In a five-person engineering study, measured muscle effort fell by 30% at slow speed.

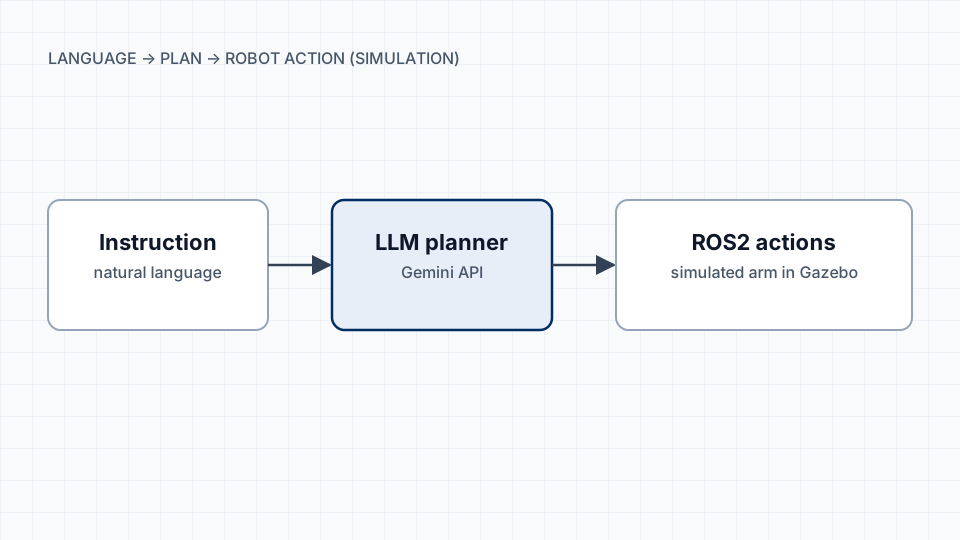
Diagram: a natural-language instruction goes to an LLM planner, which produces ROS2 actions for a simulated arm in Gazebo.

LLM-powered robotic task planning

Personal experiment: natural-language instructions become ROS2 actions for a simulated arm in Gazebo, using the Gemini API. Early stage.

June 2026 – LLM Planning & New Directions

Working on LLM-powered task planning, exploring VLA models, and building a sim benchmark.

June 1, 2026 · 1 min · Mahdi Sarfarazi

Starting This Blog

This blog is a place for concise technical notes from my work in AI and robotics. The topics I plan to write about include ROS2 software architecture, reinforcement learning for control, Isaac Gym and Gazebo simulation workflows, multimodal robot data pipelines, and the practical details of connecting LLMs and VLMs to robotic systems. My goal is to keep the writing useful: implementation notes, design decisions, experiments, lessons from hardware integration, and research summaries that can help another engineer reproduce or improve the work.
May 27, 2026 · 1 min · Mahdi Sarfarazi

ROS2 Simulation and System Log

A short log entry covering ROS2 simulation updates and system observations.

January 18, 2025 · 1 min · Mahdi Sarfarazi