LLM-powered robotic task planning
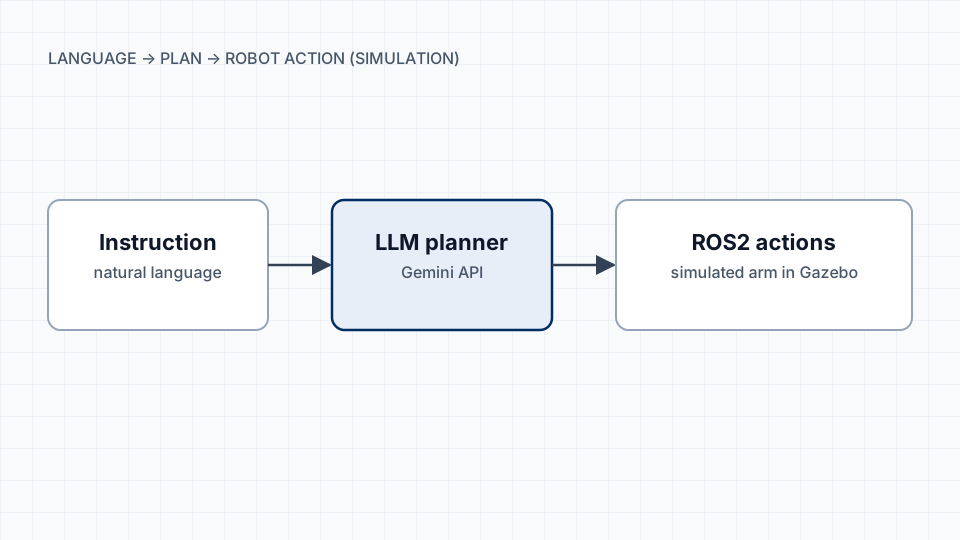
Personal experiment: natural-language instructions become ROS2 actions for a simulated arm in Gazebo, using the Gemini API. Early stage.
Personal experiment: natural-language instructions become ROS2 actions for a simulated arm in Gazebo, using the Gemini API. Early stage.
Working on LLM-powered task planning, exploring VLA models, and building a sim benchmark.