Camera-only 3D tracking and velocity estimation

Single-camera 3D multi-object tracking with YOLO11n, ByteTrack, Depth Anything V2 and a 6-state Kalman filter. Components benchmarked on a laptop GPU; no ground-truth depth, so no end-to-end accuracy claim.
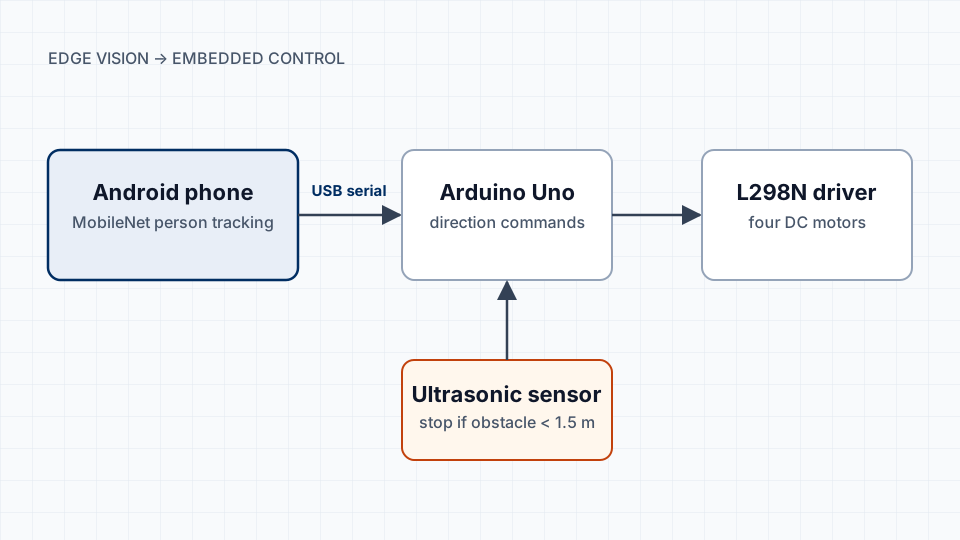
Diagram: an Android phone sends direction commands over USB serial to an Arduino Uno and L298N motor driver, with an ultrasonic sensor that can stop the robot.

Human-following mobile robot

Course project: on-phone person tracking drives an Arduino-based four-wheeled robot, with an ultrasonic safety stop at 1.5 m.